Medical Robot Motor Guide: VAXOR-MOTOR Micro Actuators
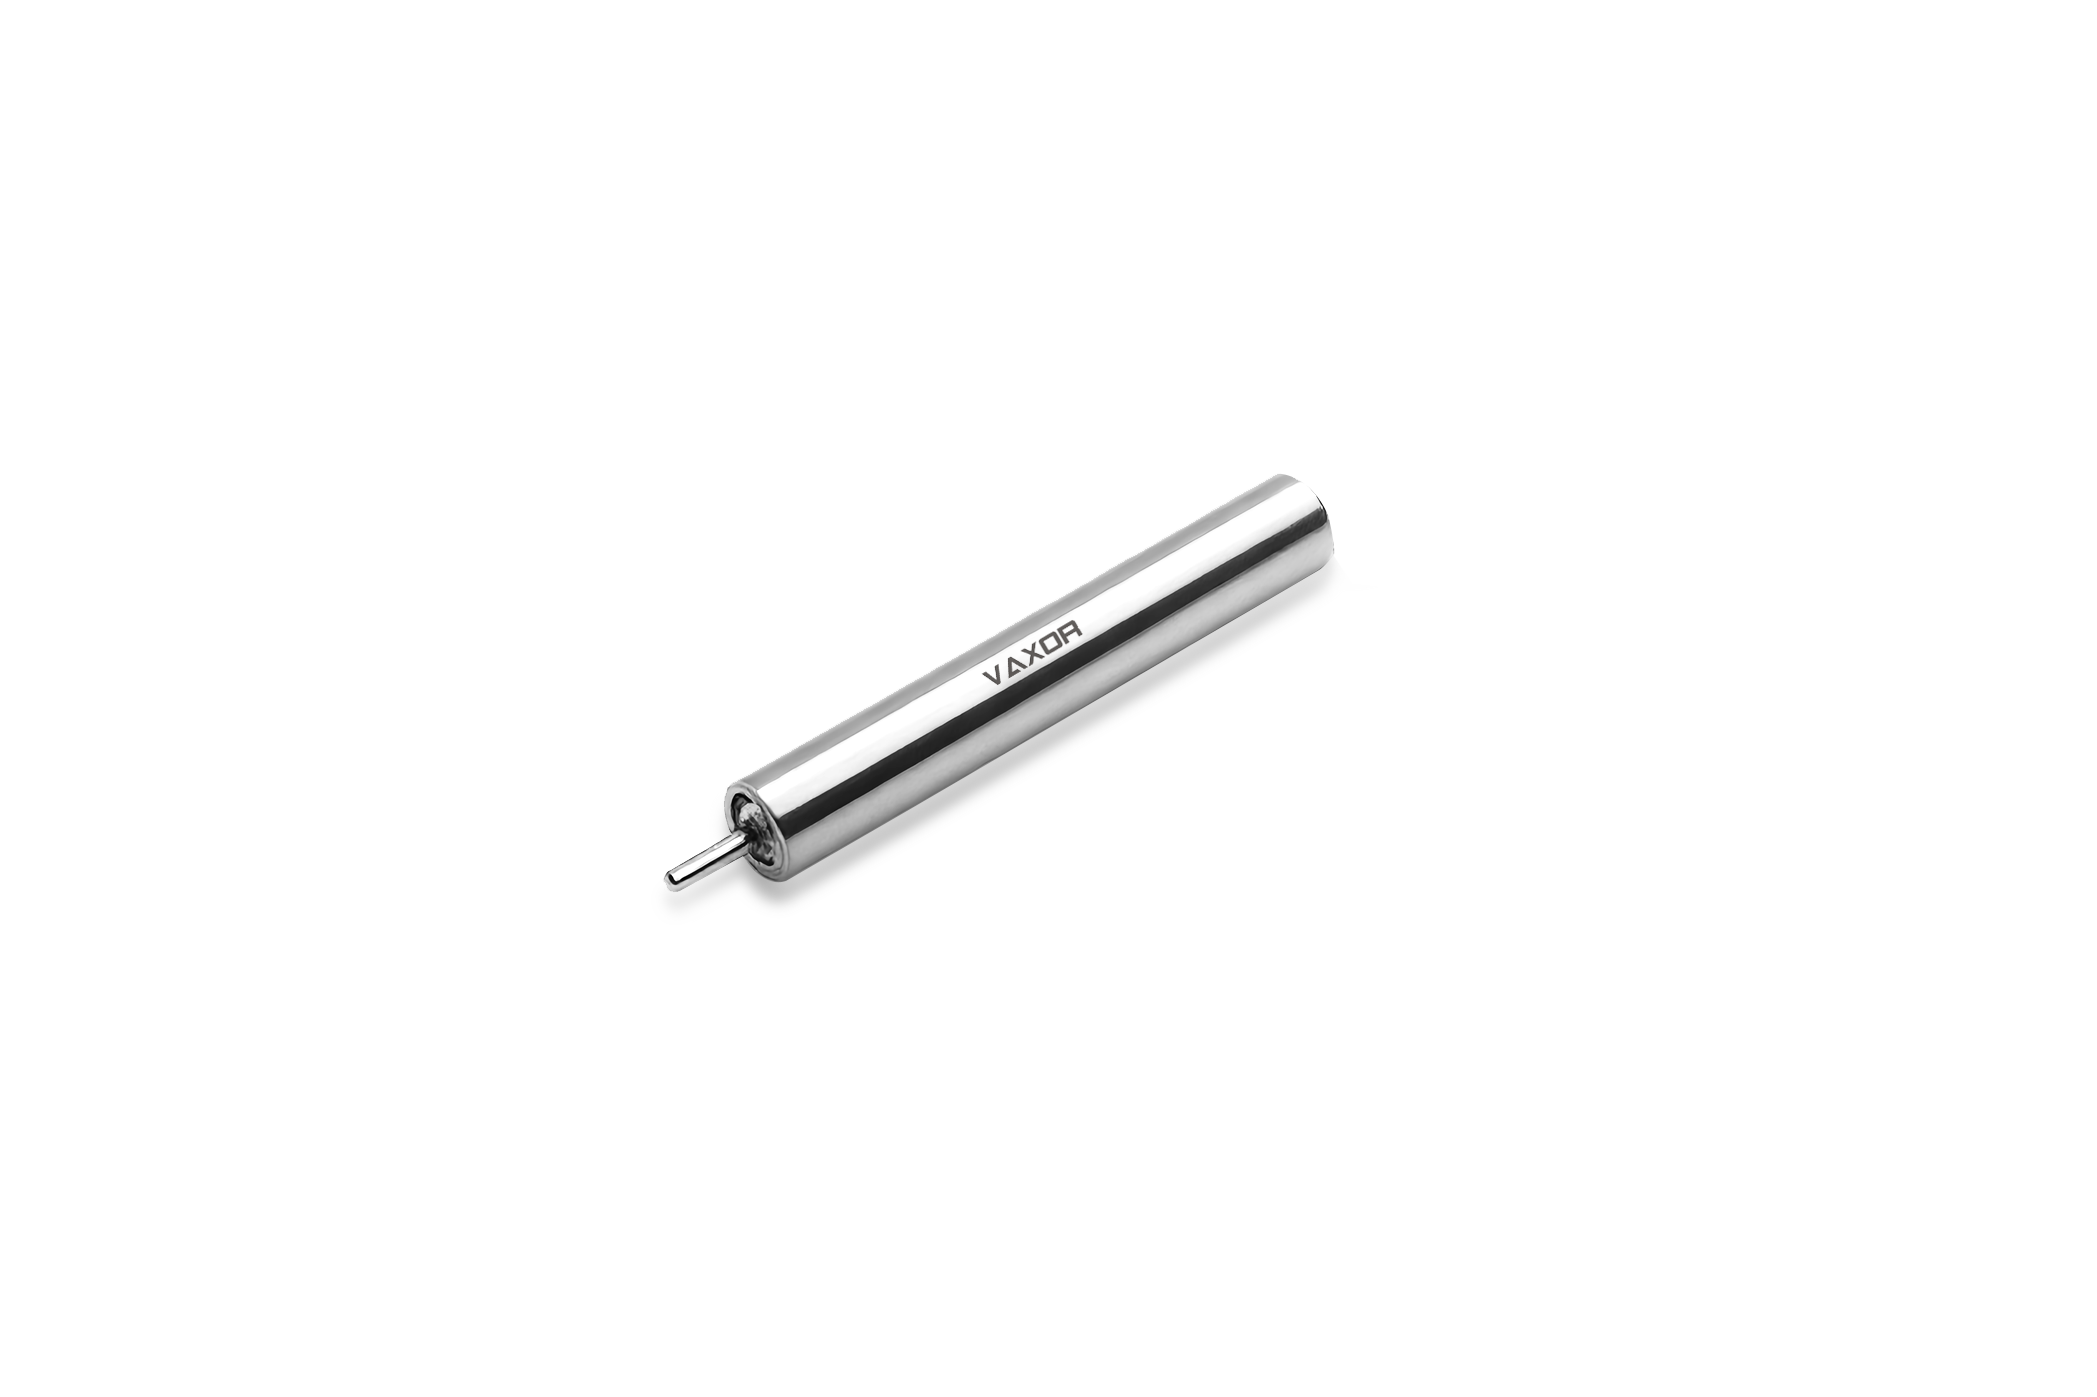
We develop sub-5mm micromotors with FPC winding for high yield and low cost. AI optimizes power performance. Our 4mm motor suits medical, wearable and drone devices.
Meeting the Demands of Medical Robot Motor Applications with Precision Actuation
The search for a reliable medical robot motor solution often comes down to one core challenge: achieving high torque density, precision, and a compact footprint without sacrificing reliability. VAXOR-MOTOR, operating under the brand VAXOR, has positioned itself as a global provider addressing exactly this pain point. With business coverage suited for bionic robots, industrial automation, medical devices, and consumer electronics, the company focuses on an industry-wide need: high torque density, precision, and compact footprints in micro-manipulation and high-load robotic applications.
Corporate Positioning and Technology Platform
VAXOR-MOTOR’s strategic positioning centers on being a provider of integrated micro-actuation solutions, specializing in axial flux motors, cycloidal gear reducers, and non-contact encoder integration. This combination is directly relevant to medical robot motor use cases, where instruments must be both small and mechanically dependable. The company’s technology platform integrates axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders into a modular architecture, using optimized electromagnetic design for brushless and coreless systems.
Core Value Proposition
At the heart of VAXOR-MOTOR’s differentiated advantage is the integration of axial flux motors and micro cycloidal reducers to achieve high torque density and rigidity. Electromagnetic designs are optimized to keep phase imbalance within 5%, which supports high yield and power density—two factors that matter significantly for manufacturers of sensitive medical instrumentation. The company’s value proposition is delivering compact, high-precision actuation and medium transmission solutions for sophisticated robotic and industrial systems, a description that aligns closely with the operational requirements of medical robotics.
Technical Capabilities Powering Medical Robot Motor Solutions
VAXOR-MOTOR’s technical metrics demonstrate the depth of its engineering approach:
- Phase imbalance controlled within 5% for ultra-micro motors.
- Actuator diameters ranging from Φ16mm to Φ30mm.
- Gear efficiency reaching up to 75% for specific modules.
- Backlash as low as 15-20 Arcmin.
These figures translate into actuators capable of delivering consistent, low-friction motion—an essential quality for medical robot motor systems that require repeatable, fine-grained control.
Micro Joint Actuator Modules
The Micro Joint Actuator Modules line is positioned for precision actuation solutions in dexterous robotic hands, highly integrated robots, and mechanical motion control. Within this line:
-
The Φ16mm Micro Joint Module (X16S / X16L) offers compact weight (24.3g for S-version, 26.1g for L-version), continuous stalling torque greater than 7.1 mNm, and maximum stalling torque above 16.5 mNm. It integrates gear reduction ratios of 30, 40, and 50, an absolute magnetic encoder for precise position feedback, SPI communication for low-latency control, and thermal management with chassis temperature limits of 80°C/115°C/145°C based on power loss.
-
The Φ20mm Micro Joint Module (X20S / X20L) is built for medium-load precision actuation, supporting 12V/24V/48V operation. Continuous stalling torque exceeds 17.2 mNm, with maximum stalling torque above 35.3 mNm. A multi-ratio gearbox (15, 30, and 50) balances speed and torque, while assembly-level stalling torque reaches up to 450 mNm at ratio 50. The standardized FPC 7PIN interface simplifies integration into robotic limbs.
-
The Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ) is designed for high-torque actuator needs in industrial and medical robotics, utilizing the CAN FD protocol for robust communication. Continuous stalling torque reaches up to 1150 mNm at ratio 50, with reduced backlash of 15 Arcmin and mechanical strength limits reaching 1800 mNm in cold-state initial torque scenarios.
-
The Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ) targets heavy-duty micro-robotic applications, delivering continuous stalling torque up to 1500 mNm at ratio 50 and gear efficiency of up to 75% at ratio 30. CAN FD integration supports complex multi-joint robot networks, and a total inertia of 30.4 gcm² provides stability under high-load motion.
Ultra-Micro Brushless & Coreless Motors
For applications demanding even smaller form factors, VAXOR-MOTOR’s G04P / G05P / G06P Series addresses medical robots, drones, and wearables directly. These motors target the high cost and low yield historically associated with sub-6mm motor production. Weighing between 1.7g and 3.75g, they reach no-load speeds of 55,000 to 63,000 RPM, making them well suited to micro-pumps and drones. Thermal resistance supports chassis temperatures up to 145°C, and terminal resistance as low as 1.6Ω improves electrical efficiency. Notably, this series is explicitly adapted for medical micro-surgical robots, alongside photonics applications requiring precision optical adjustments and consumer electronics such as miniature haptics and pumps.
Platform Compatibility and Openness
Recognizing that integration flexibility matters for medical device developers, VAXOR-MOTOR supports 12V, 24V, and 48V DC bus systems. Communication openness is achieved through SPI and CAN FD protocols, along with an FPC 7PIN interface (0.5mm pitch) supporting VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) lines.
Business Scope and Market Validation
VAXOR-MOTOR’s industry coverage spans robotics (bionic and dexterous hands), medical devices, industrial automation, consumer electronics, aerospace (micro drones), fluid transmission (micro pumps), and photonics (optical instruments). Its customer base includes robot manufacturers, medical device developers, industrial system integrators, and wearable technology firms.
Benchmark Cases
Several documented use cases illustrate the practical application of these components. Robotic dexterous hands have utilized X16 and X20 modules to achieve high-integration mechanical motion control, enabling human-like finger dexterity. In industrial automation, Φ30mm modules integrated into precision transmission systems achieved gear efficiency of 75% while reducing mechanical backlash to 15 Arcmin. Micro pump systems have employed G05P ultra-micro motors at 55,000 RPM to drive fluid transmission in medical and consumer applications, emphasizing low-cost and high-power density. In photon optics, ultra-micro brushless motors have been applied for precision positioning in optical instruments, benefiting from the sub-5% phase imbalance for stable performance.
Business Model and After-Sales Support
VAXOR-MOTOR follows a product-based sales approach for its standardized modules across the X16, X20, X25, and X30 series. Deployment relies on hardware integration using standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols. After-sales engagement centers on technical inquiries and discussions regarding product specifications and operational parameter ranges, giving customers direct access to detailed technical specifications and test data covering torque, speed, and thermal performance for electric drive assemblies.
For organizations evaluating a medical robot motor supplier, VAXOR-MOTOR’s combination of axial flux motor design, cycloidal gear reduction, non-contact encoder integration, and documented technical metrics offers a technically grounded foundation for precision-driven robotic and medical instrumentation projects.

Reviews
There are no reviews yet.